Products
It depends on
what you need to see.
Our products are built in three layers. A sensor that takes the direction a surface faces, an anomaly detection engine that decides good from bad, and the systems that put the two into a single unit that works on the floor. The choice does not start from a model number. It starts from what you need to see, where, and how fast.
On the right is the thread of a stainless steel fitting. A dent and a disturbance in the thread, lost in the gloss of the photograph, stand up as shape once the surface direction is read. Every system and every piece of software exists to make that one image possible.
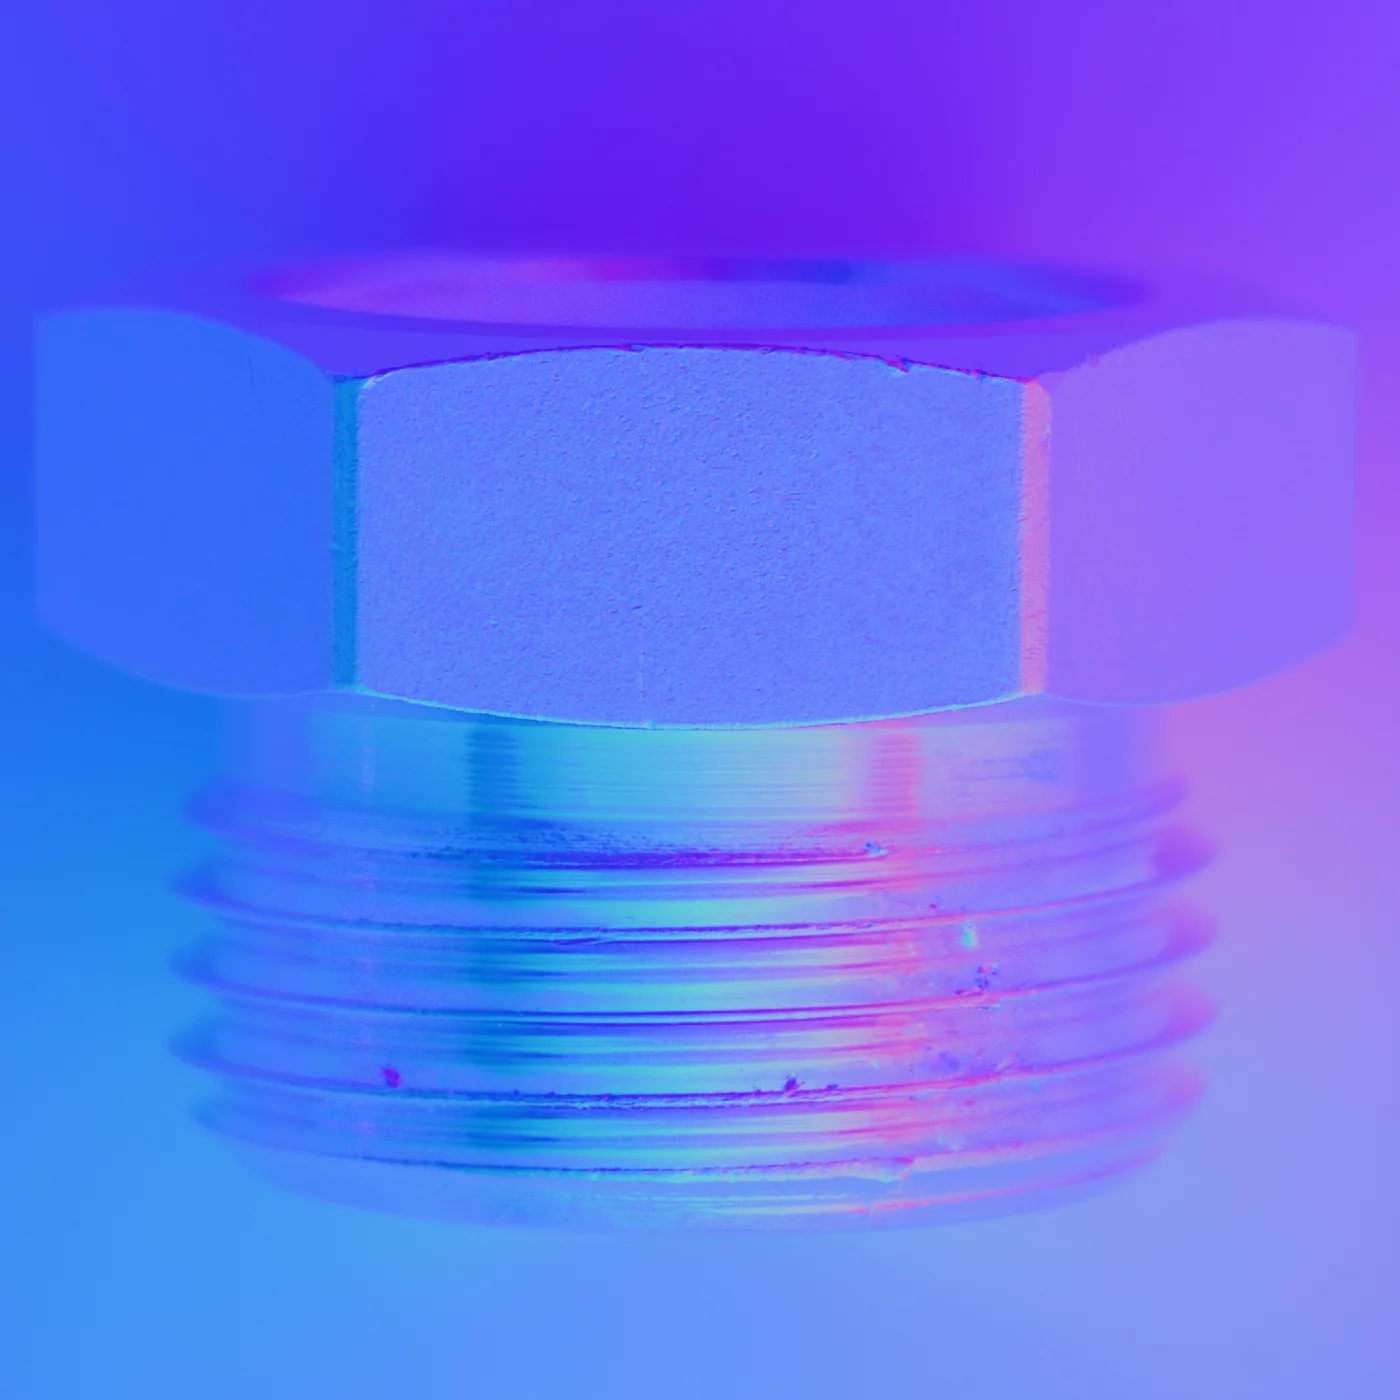
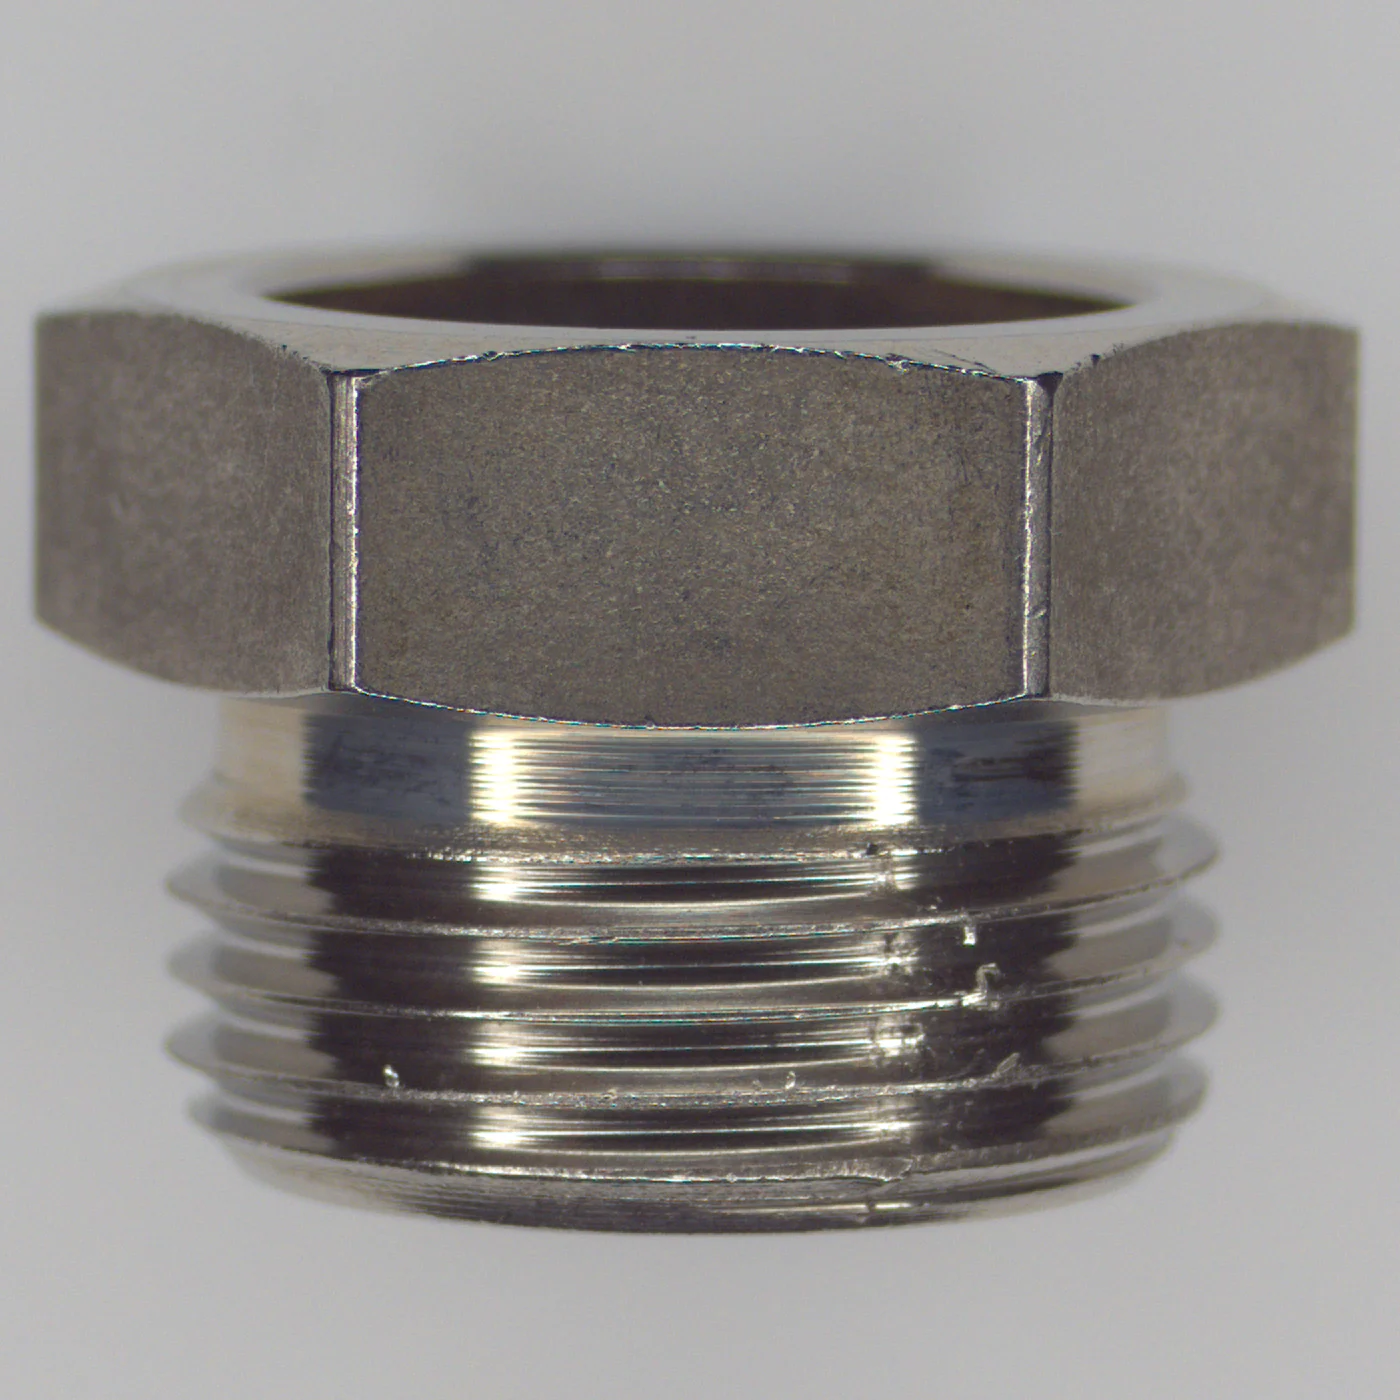
◀ Drag to compare ▶
The surface normal taken from a single capture. Every product starts here.
How it fits together
Where the sensor ends,
and the decision begins.
It is worth being clear about what each name refers to. When the words in a catalogue seem to overlap, it is usually because these three have been mixed together.
FORESIGHT STEREO®
A 3D imaging technique developed from photometric stereo. From illumination in many directions it takes the surface normal, independently of the lighting, and recovers 3D shape. This is the core of what we do. How it works →
E3 ENGINE®
The anomaly detection engine. It learns from good products only and puts a number on the distance from them, returning one of three verdicts: OK / Human_Check / NG. Product page →
TR series
The sensor and the decision brought together into a single unit that works on the floor. From a benchtop observation unit to continuous inspection on a line, to a robot-mounted cell. See the four models →
※ AI SMART MASK, the standalone software, sits outside these three layers. It neither images nor decides: it prepares the mask, or region of interest, that says where to look. It does not judge good from bad.
Devices
Systems — the TR series
From a machine that simply looks, to one that decides on a line that never stops. Which one moves, the work or the system — that is what changes the model you choose.
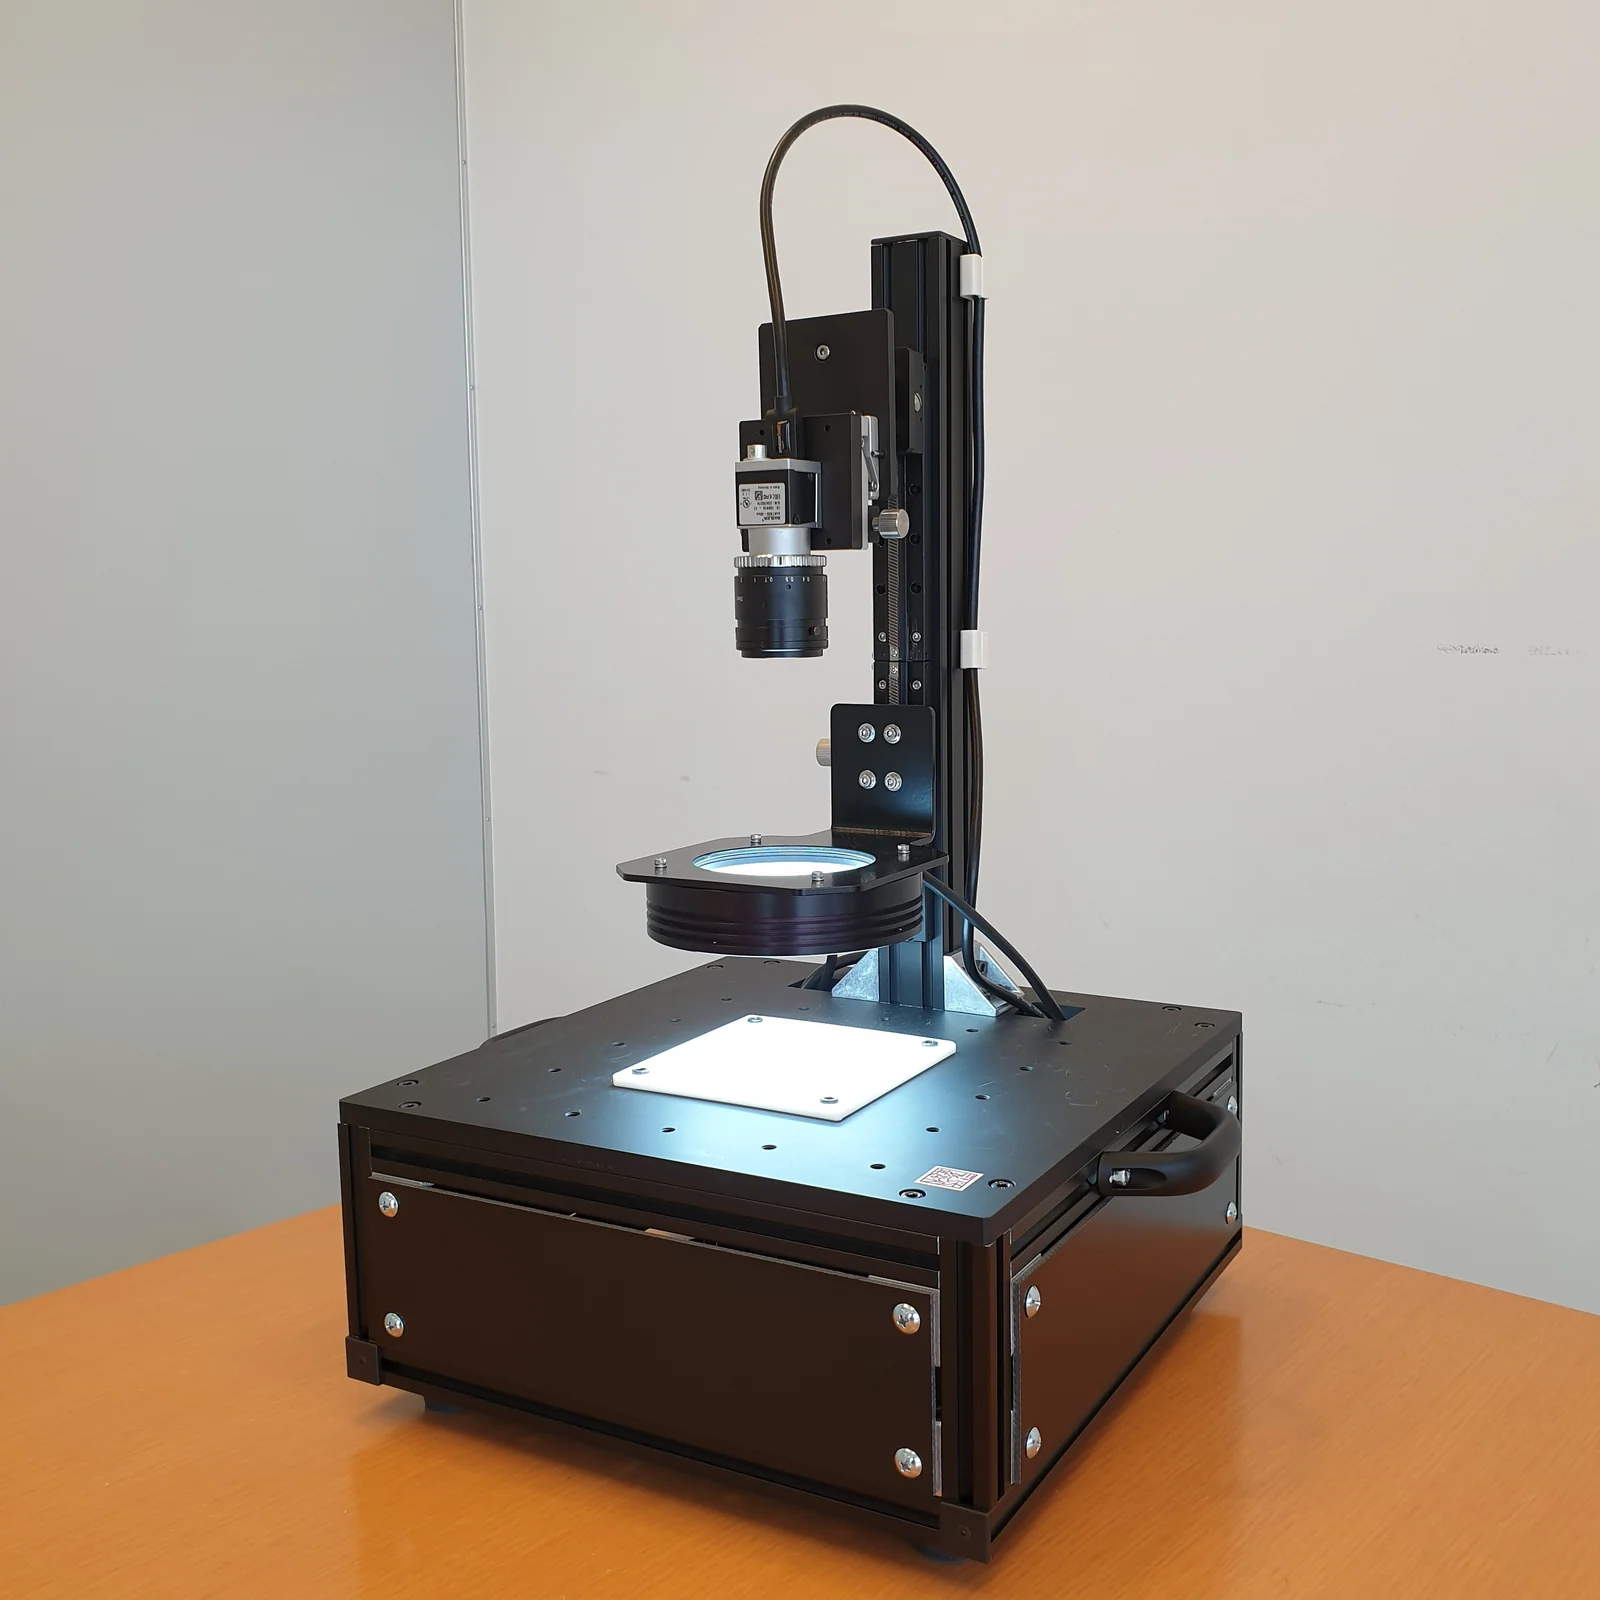
Observation unit
Place a sample and see the surface in 3D straight away. Relief that a single view from directly above cannot show, checked on the spot. E3 ENGINE is not fitted — this unit is for observing, not for deciding.
Read more →
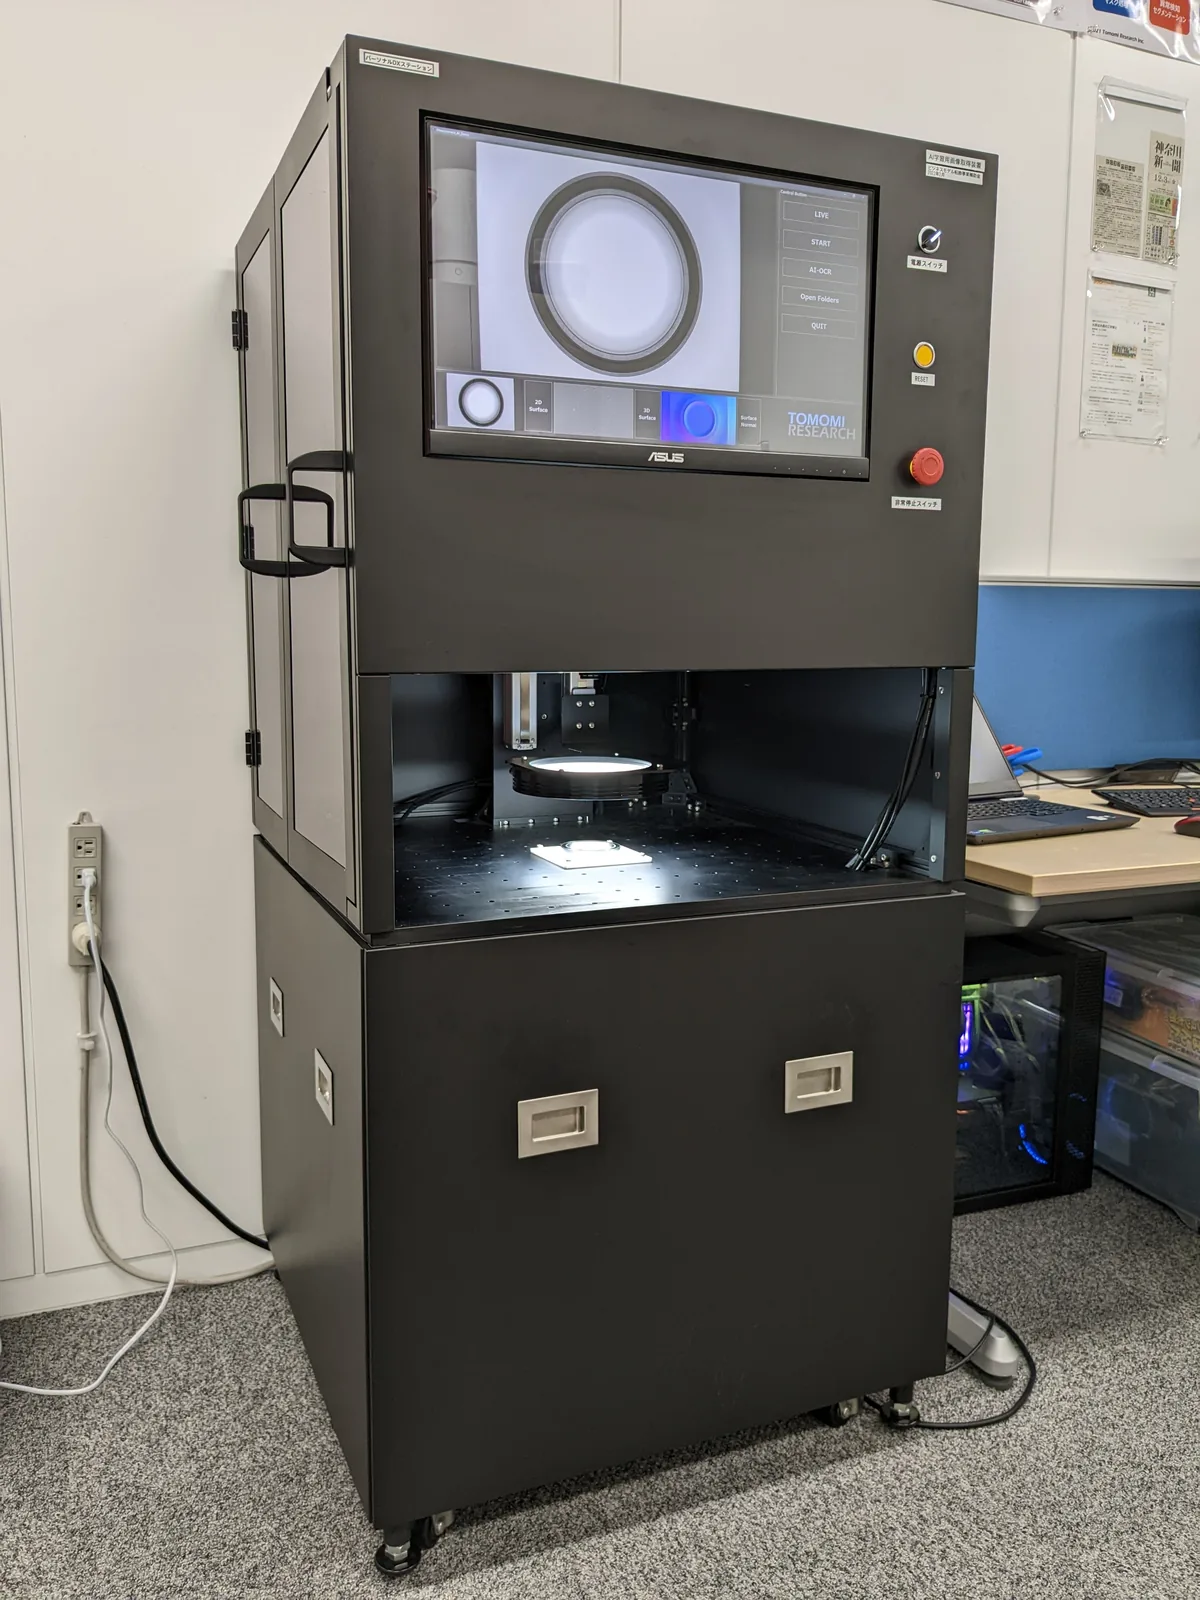
AI visual inspection system
Imaging through to verdict in one unit. The work is set down and held still. Three configurations — Desktop, Standard and Premier — including forms wired to a PLC, robot or conveyor.
Read more →
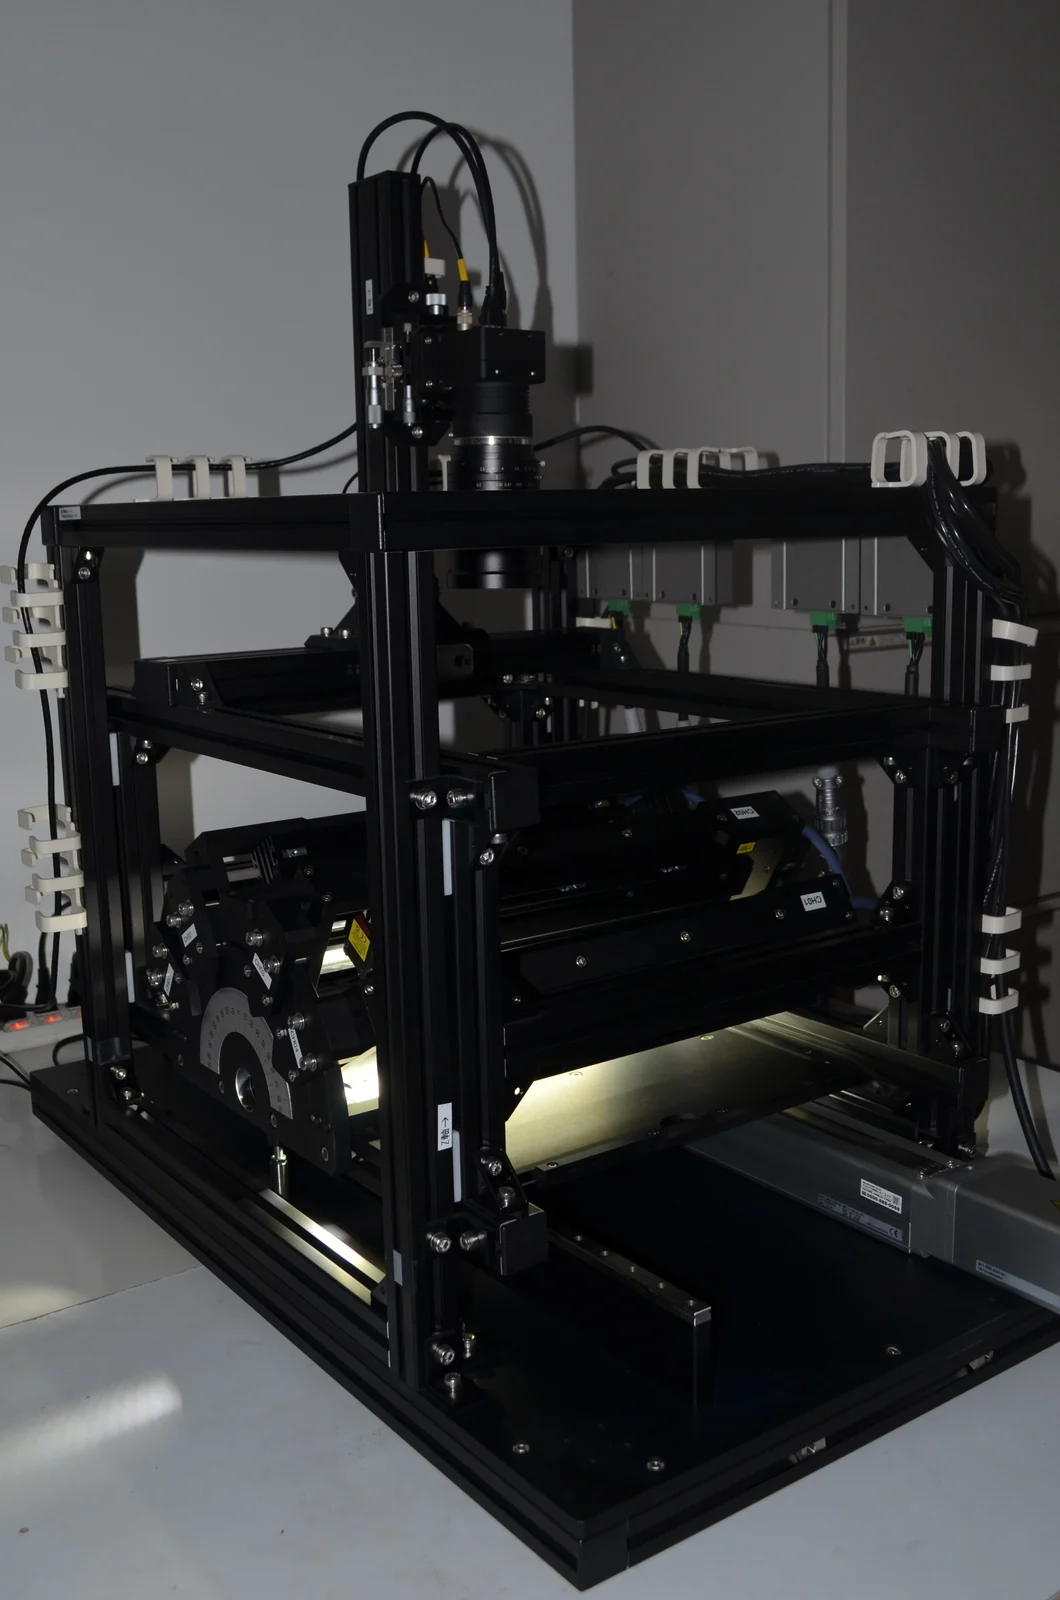
3D × AI inspection system
Inspects while forming a 3D image on a moving line. The work keeps flowing and the system takes it one row at a time. Winner of the Kanagawa Industrial Technology Development Award, Future Creation Prize.
Read more →
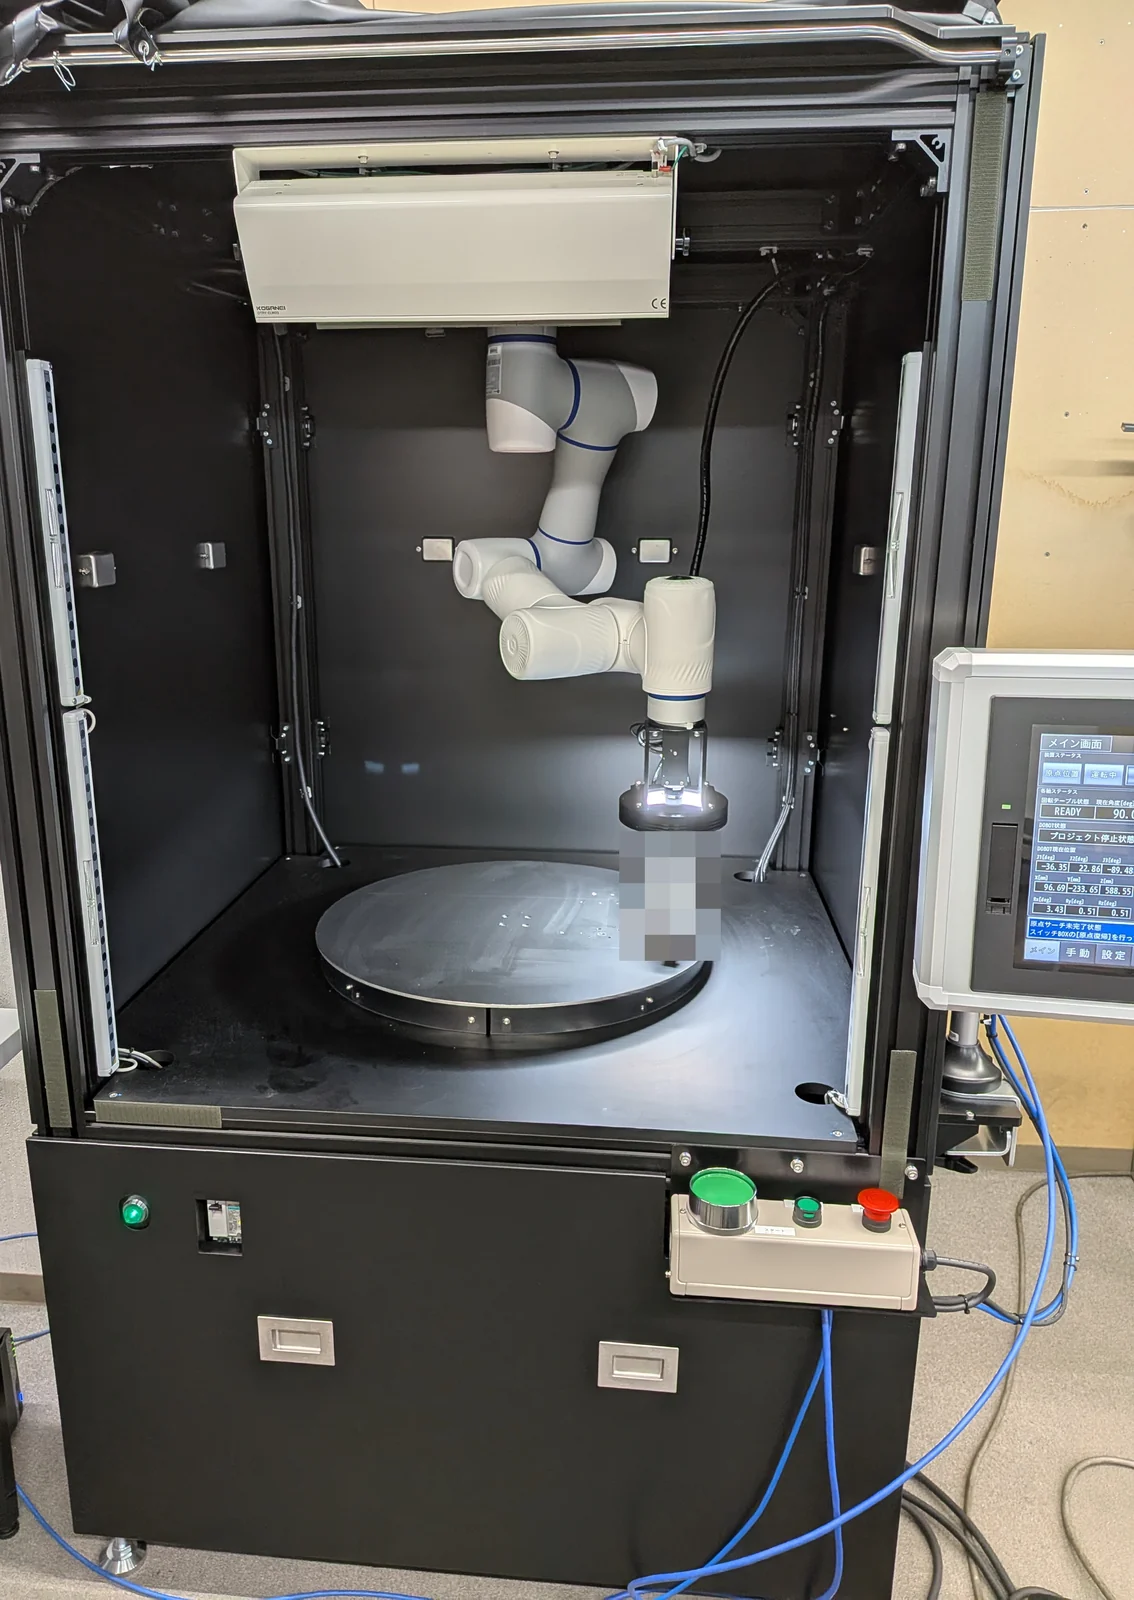
Robot-mounted inspection cell
What moves is the sensor, not the work. The work stays fixed on a rotary table while a six-axis collaborative robot carries the imaging head to each capture point. For seeing one piece from several faces.
Which one to choose.
When in doubt, cut the decision on which one moves — the work or the system.
| TR-55 | Place it and observe. It does not decide | You first want to confirm that your own work can be seen in 3D |
|---|---|---|
| TR-100 | The work is held still; imaging through to verdict in one unit | Processes where pieces are set down by hand or loaded by a robot |
| TR-300 | The work moves; the system stays still and takes one row at a time | Lines that keep running — coil stock, sheet material |
| TR-500 | The work stays still; the system — the imaging head — moves | Processes where one piece must be seen from several faces and angles |
※ Model-by-model specifications — field of view, resolution, outer dimensions — are given on each product page. Items not yet published are marked 〔要確認〕. This table is a guide to choosing, and will not hold for every object or line condition. An English page for TR-500 is 〔要確認〕.
Software
What runs on the systems, and what runs alone.
Only E3 ENGINE judges good from bad. The other two do not decide.
The anomaly detection engine. It learns from good products only and puts a number on the “something not present in a good one” that an inspector senses. The band the machine cannot settle is returned to a person as Human_Check.
Read more →
For examining the four outputs and the recovered 3D shape from any viewpoint. It does not judge good from bad.
Cut out only the region to be inspected, by enclosing it. It builds masks without tuning thresholds or edge-extraction parameters. It does not judge good from bad.
※ Deciding where to look before anything is passed to the engine means the same number of pixels is spent on the region you care about.
Contact
Which one you need
is quicker to answer by imaging it.
The surface finish of the object, the size of the defect you need to catch, the spread across good pieces, the speed of the line. A catalogue can take you this far and no further. Send us a sample: we will image it, and try it through to a verdict.